A dynamical systems perspective on Templates & Anchors: some general methods for anchoring templates
IEEE International Conference On Intelligent Robots and Systems, Workshop on Robotics Inspired Biology, 2017
Abstract
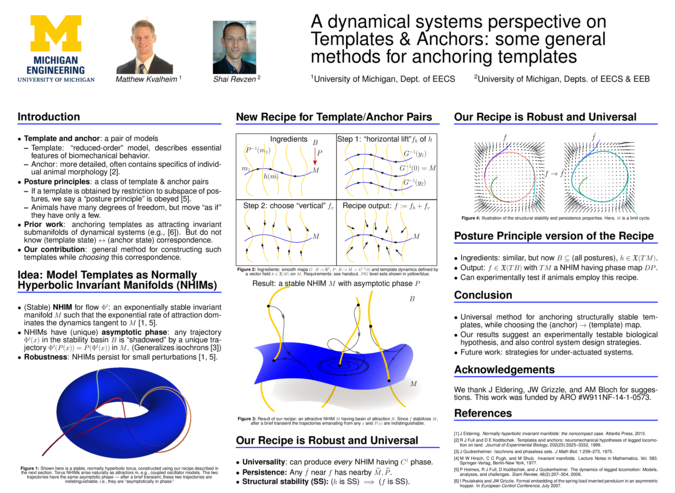
A template and anchor are a pair of models such that the template describes the essential features of a biomechanical behavior, whereas the anchor is a more detailed model that often contains specifics of the individual animal morphology [FK99]. Many biomechanical behaviors are well-approximated by template models, which is to say that animals have many degrees of freedom, but move “as if” they have only a few. Control theory as used in robotics and the related dynamical systems theory provide a mathematical frame- work wherein smooth templates can be described as attracting normally hyperbolic invariant manifolds (NHIMs) [HPS77], [Eld13]. NHIMs (i) persist under perturbations, so are physically relevant, and (ii) come equipped with a natural “asymptotic phase” reduction map which faithfully relates (semi-conjugates) anchor states to their template representation [BK94]. This map generalizes the classical notions of asymptotic phase and isochrons for a nonlinear oscillator [Guc75]. We present a systematic procedure for anchoring such smooth templates M within an anchor B. Our recipe includes the ability to choose the asymptotic phase map P: B \to M, as well as arbitrary smooth template dynamics g: M \to TM. See Figure 1. Our result is universal: every attracting NHIM possessing smooth asymptotic phase arises from our construction. For some biological systems satisfying a “posture principle” (as defined in [HFKG06]), our results construct a force law that anchors such a postural template.
BibTeX
@conference{kvalheim-2017-iros,
  author = {Kvalheim, M and Revzen, Shai},
  title = {A dynamical systems perspective on Templates \& Anchors: some general methods for anchoring templates},
  booktitle = {IEEE International Conference On Intelligent Robots and Systems, Workshop on Robotics Inspired Biology},
  year = {2017},
  url = {https://gravishlab.ucsd.edu/iros2017/posters/Kvalheim_abstract.pdf},
}